We use technically necessary cookies so that our website works. With your consent, we also use Google services for statistics and marketing (Google Analytics, Google Ads) for reach and performance measurement as well as personalised advertising, and embed external media such as YouTube videos. In the process, data may be transferred to Google LLC in the USA (EU-US Data Privacy Framework, Art. 45 GDPR). You can change or withdraw your choice at any time under “Cookie settings” (at the bottom of every page). More in our privacy policy.
Provider: Google Ireland Limited (Ireland), YouTube/Google. When the video is loaded, data, in particular your IP address, is transmitted to YouTube/Google; cookies may be used in the process. A transfer to Google LLC in the USA is possible (EU-US Data Privacy Framework, Art. 45 GDPR). “Load YouTube video” starts this video. If cookie settings are available, the click also counts as consent to the category External media / videos. If the choice is saved in the browser, it applies for up to 12 months; otherwise only for this page. With your consent, selected videos can load automatically and muted: only in the visible tab, without reduced motion and without a manual stop. You can withdraw consent in the cookie settings. Privacy notice Automatic, muted loading only after consent to external media. Can be changed under Cookie settings.
Epson G10-854SR Robot Screwdriving Station Dosing Station
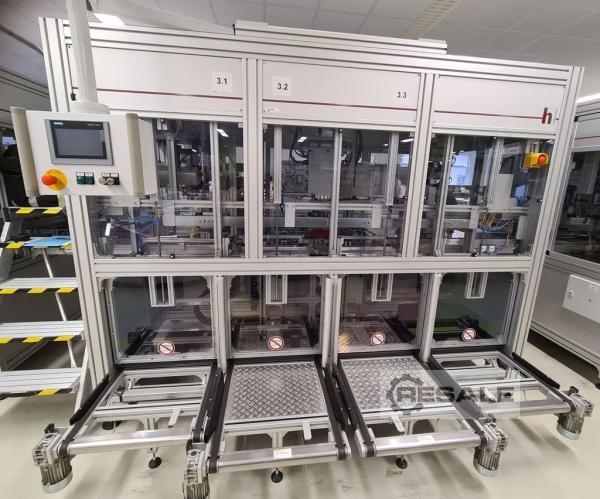
Assembly of parts for car radios and navigation systems and for testing them.
The assembly station is designed as a closed aluminium frame with a steel welding frame inserted and has a very compact design.
The control cabinets and valve terminals are integrated into the system.
All movement processes during the operation of the system can be tracked on all sides through large windows and doors.
Operation is via a touch screen.
The assembly station is divided into substations 3.1 dosing area, 3.2 assembly area
KK+SW and 3.3 mounting area front. (KK=heat sink, SW=bulkhead angle)
The work steps according to these assembly areas are described below:
St.3.1: Dosing range
- a WT with attached chassis and printed circuit boards enters the dosing area via the transfer belt.
- this is stopped at the stroke positioning unit (HuPo) and lifted off the belt and fixed
- now the x-y-z handling will move the dosing head to the intended location and start the dosing process.
- after completion of the successful dosing, the handling moves over the rest position and the WT is placed on the belt
- Further transport to the assembly area KK+S\WV (prerequisite no WT in assembly position)
The dosing quantity can be selected in the control of the dispenser (Scheugenpflug) and via the PLC depending on the position
The positions can be viewed via the control panel
St.3.2: Mounting area KK+SW
- via the transfer belt, a WT runs from the dosing area into the KK+SW assembly area.
- this is stopped at the stroke positioning unit (HuPo), lifted off the belt and fixed, while the chassis side walls of the partially assembled assembly are aligned
- at the same time the KK tray and SW tray positioning takes place
- a KK tray stack (12) and a SW tray stack (12) are manually placed outside the protective enclosure on the respective infeed belt
- the two safety bulkheads are opened and the loaded tray stacks run into the gripping position of the respective forklift
- the two security bulkheads are closed again
- the respective grippers grip the corresponding tray
- with the z-axis the tray separation and the transport upwards takes place (over the actual height of the removal)
- for centering and tray stabilization, a centering support is pushed and positioned under the respective tray by means of x-handing.
- with the forklift z-axis, the respective tray is placed on the corresponding centering pad
- the trays are ready for removal of the components
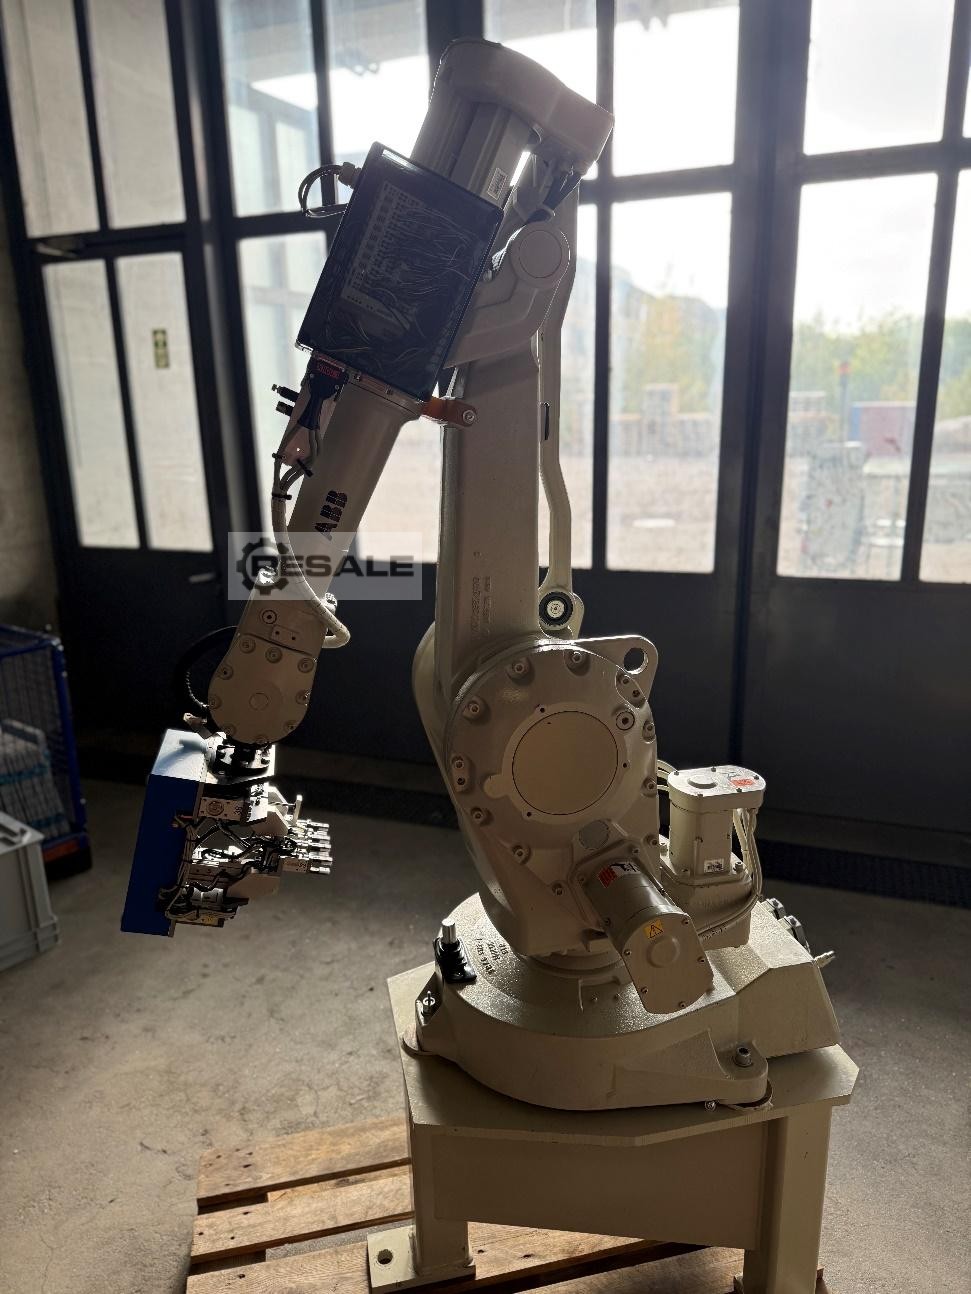
- with the multiple gripper on the Scara robot, the KK is gripped in the tray and placed in an intermediate position as an alignment aid (in order to achieve inaccuracies when picking up from the missing gripping position for assembly)
- the KK is scanned, grabbed again and installed on the WT if the result of the scanner is OK
- the n.i.O. KK is stored in an n.i.O. box
- the multiple gripper on the Scara robot then grabs the SW in the tray and places it in the alignment position
- the SW is grabbed again and installed on the WT
- continue with mounting area front
- if the provided trays are empty, they are stored on the corresponding rejection belt
- for this purpose, the forklifts are positioned accordingly by means of x-axes
- the empty trays are only rejected when the complete tray stacks have been processed
- the corresponding safety bulkheads are opened and the empty tray stacks are discharged for manual removal
- the two security bulkheads are closed again
St.3.3: Mounting area front
- the front is positioned on the circumferential WT in a separate nest
- with the multiple gripper on the Scara robot, the front is removed from the WT equipped with KK and SW in the KK+SW assembly area
- the front is positioned in the nest of a mounting unit
- the WT runs over the transfer belt from the assembly area KK+SW to the mounting area front and is stopped by the hub positioning unit, lifted off the belt and fixed, while the chassis is held down
- the positioned front is joined by a rotary lifting movement on the WT
- after completion of the successful front assembly, the assembly unit moves to the starting position and the WT is placed on the belt
- continue > Station 4
Inquire about this machine
Your inquiry goes directly to the seller of this machine.